Back to All Buyer's Guides Sectors

Industrial Web Search Buyer's Guide Sector

Industrial Robotics & Integration

Robot arms, mobile robots, and the engineering that turns them into working production cells: end-of-arm tooling, safeguarding, part feeding, programming, and commissioning. This sector covers the robots themselves, the integrators who design and deliver cells, the tooling and peripheral specialists around them, and the safety standards and acceptance practices that determine whether an automation project succeeds.

Overview

Types of Industrial Robots, Integration, and Who Supplies Them

A working orientation to the sector before you request proposals: what you are actually buying, what governs whether it works, and the kinds of company you will end up talking to.

The first thing to settle is what you are buying, because in this sector the robot is rarely it. A robot is a catalog product: articulated six-axis arms, an axis being one independent joint of motion, for general work, four-axis SCARA and overhead delta robots for fast pick-and-place, and mobile robots, guided or autonomous, for material movement. A cell is the robot plus the end-of-arm tooling, fixtures, part feeding, safeguarding, controls, and programming that enable it to perform your task. Integration is the engineering service that designs, builds, proves, and commissions the cell. Most buyers are purchasing a cell as part of an integration project, and the robot accounts for a minority of the total. Machine vision, motion components, and conveyors each have their own sectors; this page covers robots, integration, and the tooling and safety engineering associated with them.

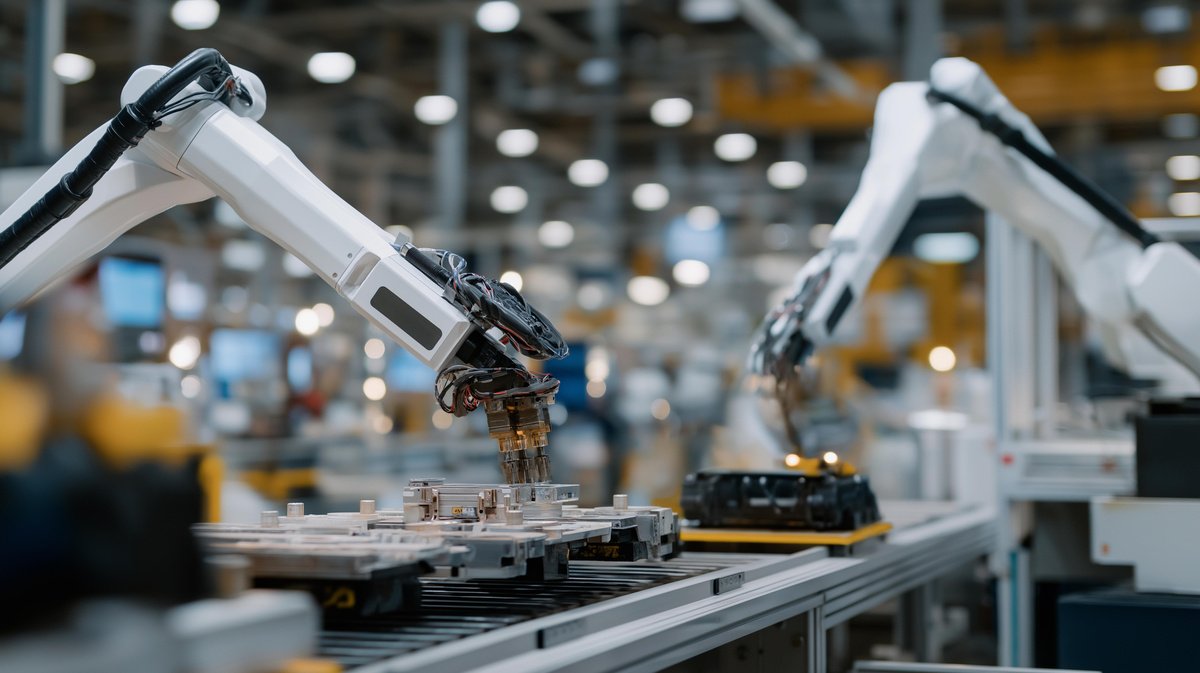
Industrial six-axis robot arm with end-of-arm tooling working in an automated production cell on a factory floor.

What governs whether it works is the task and the risk assessment, in that order. The task, honestly described, sizes everything: the parts and their real variation drive the tooling and feeding, which are routinely the hardest engineering in the project; the rate drives the robot class and the cell design; the process drives the quality criteria on which acceptance will be judged. The risk assessment then determines the safety design, because under the current safety standards, the assessment of your specific application, not the robot's marketing, decides the safeguarding, the required performance of every safety function, and whether people and the robot can share space. The current revision of the safety standards folded collaborative requirements into the main robot standard and made collaborative formally a property of the application, so which editions a proposal cites tells you whether its safety engineering is up to date.

Five kinds of company supply this sector. Robot manufacturers make the arms and controllers, sold directly and through distributors, with published payload, reach, and repeatability. Buying through a distributor changes the conversation, not the robot: distributors carry stock, price, and basic application support, and refer integration out to partners, so a distributor is neither the manufacturer's engineering department nor an integrator, and knowing which of the three you have called saves a mismatched conversation. System integrators engineer and deliver cells, own the risk assessment, and are the supplier most buyers actually need; association certification programs exist for them, and their application experience matters more than their size. End-of-arm tooling and peripheral specialists design and build grippers, tool changers, feeders, and fixtures to the integrator's order or yours. Mobile robot suppliers provide vehicles and fleet software, with deployment engineering that is as much a part of the purchase as the vehicle. Service providers handle training, maintenance, relocation, and refurbishment of installed cells. It also tells you what to search for: a defined task with variable parts means integrators; a robot model you have already chosen means the manufacturer or its distributors; a gripper or tool for an existing robot means tooling specialists; material movement means mobile robot suppliers with deployment engineering; and an existing cell that needs help means service providers. The distinction determines who owns the risk assessment, who guarantees the cycle time, and whose project management you are betting on.

Sourcing Considerations

How to Choose Robotics and Integration: 6 Things to Get Right

The decisions below are the ones that most often cause regret later. The first two, the honest task definition and the choice of integrator, determine everything after them, including the answers to the other four. The detail sits in the guides at the bottom of this page.

01

Define the task and the parts honestly before anyone quotes

Describe what the cell must do, at what rate, across which part variants, and with how much variation in how parts arrive, because part presentation is where automation projects live or die. Simplifying presentation and reducing variants before automating often does more for the price than any negotiation. A task defined optimistically produces a cell that works in the demonstration and struggles on your floor.

02

Choose the integrator with more care than the robot

For most applications, several robots would work, and only a well-run project will. So evaluate integrators on applications like yours: cells delivered, references running at the rate, simulation practice, safety engineering, and project management. Ask who owns the risk assessment, who programs, and who supports the cell afterward. Certification programs exist, and help, but a reference cell still running on your kind of task is the evidence that matters.

03

Size the robot with the tooling on it

Payload is consumed at the flange by tooling, cables, and sensors before the part counts; usable reach shrinks with orientation and tooling length, and repeatability figures are comparable only under the standardized performance test. If the application is offline-programmed or vision-guided, it depends on accuracy, which is less reliable than repeatability and is rarely published, so state the need explicitly. Require the cell to be simulated before hardware is ordered.

04

Treat safety as engineering with deliverables, not a product feature

Require the documented risk assessment for your application, the safeguarding design it produces, and the table of safety functions with required and achieved performance levels as named contract deliverables. Treat collaborative operation as a result of the assessment validating your task and tooling, never a robot property, and check that proposals cite the current editions of the safety standards, because the collaborative requirements live in the main standard, not a separate specification.

05

Give end-of-arm tooling and feeding their own attention

The tooling is custom to your part, routinely the hardest engineering in the cell, and a frequent source of schedule risk, and feeding grows expensive exactly as parts arrive less predictably. Review the tooling concept and the feeding approach as deliberately as the robot selection, specify the standard flange interface. Hence, tooling remains portable, and count every gram of it against payload. A brilliant robot behind a bad gripper is a bad cell.

06

Define acceptance before you sign, and test at the factory first

Agree factory and site acceptance criteria in the contract: cycle time at rate with your real parts across their actual variation; quality measured as production will measure it; availability over a defined run; verification of every safety function; and delivery of documentation, programs, the risk assessment, the spare parts list, and training. Tie payment milestones to both tests, and do not compress the factory test, because problems found there cost days and the same problems on your floor cost weeks.

Glossary

Industrial Robotics Glossary: Key Terms Explained

The terms you will meet on a robot datasheet, an integration proposal, or a safety document, in plain English.

26 terms

AMR and AGV

The two families of industrial mobile robots. An automated guided vehicle follows fixed guidepaths; an autonomous mobile robot navigates by sensing and planning around obstacles. They descend from different standards traditions, and which safety standard a vehicle is designed to meet tells you how it is expected to behave around people, so ask for it by name.

Articulated robot

A robot arm with rotary joints, most commonly six axes, giving it the dexterity to approach a point from many orientations. It is the general-purpose configuration of industrial robotics, and its published payload, reach, and repeatability are the datasheet numbers every application is screened against first.

Cell

The complete working installation around a robot: the robot, its end-of-arm tooling, fixtures, part feeding, safeguarding, controls, and the process equipment it serves. The cell, not the robot, is what performs the task and is what the integration standards evaluate; it is usually what you are actually buying.

Collaborative operation

Operating methods that allow people and robots to share a workspace safely, defined in the current safety standards as a property of the application, not of the robot. A robot marketed as collaborative still requires a risk assessment of the actual task, tooling, and part, because a safe robot carrying a sharp part is not a safe application.

Cycle time

The time for the cell to complete one full task cycle, which, with availability, determines throughput. It is the number the business case rests on, and it should be specified at rate, with your real parts, as an acceptance condition, because a demonstration cycle on ideal parts is not a production cycle.

Degrees of freedom

The number of independent axes of motion, six being sufficient to place a tool at any position and orientation within reach. Fewer axes cost less and run faster where the task allows, and auxiliary axes, such as rails and positioners, add freedom at the cell level rather than at the arm level.

Delta robot

A robot with lightweight parallel arms hanging from an overhead base, built for very fast pick-and-place of light parts over a small area, the configuration behind most high-speed packaging and food lines. It trades payload and reach for speed, which is why it belongs in the same conversation as the SCARA rather than the articulated arm: both are shape-of-task robots that beat a six-axis arm where the task fits and cannot leave their niche where it does not.

End-of-arm toolingEOAT

The gripper, tool, or process head mounted on the robot's flange, custom to the part and the task. It is routinely the hardest engineering in the cell and a frequent source of schedule risk because the robot is a catalog product, whereas the tooling is not. Its weight and inertia count against the robot's rated payload.

FAT and SAT

Factory acceptance testing, run at the integrator's site before shipment, and site acceptance testing, run after installation, each against agreed criteria. Together they are how a cell is proven: cycle time at rate with your parts, quality outcomes, safety function verification, and documentation, with payment milestones usually tied to both.

Integrator

The company that engineers the cell: selecting the robot, designing tooling and safeguarding, programming, and commissioning, and taking responsibility for the risk assessment and the working result. Integration is the service most buyers in this sector are actually purchasing, and integrator selection matters more than robot brand for most applications.

Machine tending

The application family in which a robot loads and unloads a machine such as a press, molding machine, or CNC. It is a common first automation project because the task is repetitive and bounded, and its difficulty concentrates in part presentation and gripping rather than in the robot.

Monitored standstill

A safety function in which the robot remains powered but is held stationary under safety-rated monitoring while a person is in the shared space, resuming when they leave. Earlier editions of the standards referred to it as a safety-rated monitored stop, and both names appear in circulating documentation.

Offline programming

Creating and validating robot programs in simulation rather than on the physical cell, reducing commissioning time and allowing cycle time and reach to be checked before hardware exists. Ask an integrator whether the cell is simulated, because a simulation is also the cheapest place to discover the robot cannot reach the part.

Palletizing

The application family in which a robot stacks products onto pallets. It is specified by the payload, including tooling, pallet pattern flexibility, and rate, and it is one of the applications where standard, pre-engineered cells exist and full-custom integration may not be necessary.

Payload

The maximum mass the robot can carry at rated performance, measured at the tool flange and consumed by everything attached to it: tooling, cables, sensors, and the part. A robot selected against part weight alone, without the tooling, is the most common sizing error in this sector.

Performance levelPL

The classification, from a to e, of how reliably a safety function must perform, determined by the risk assessment and delivered by the design of the safety-related controls. The required level is an output of the assessment of your application, not a robot datasheet property, and the integrator must show the achieved level meets the required one.

Power and force limiting

The collaborative operating method in which contact between robot and person is permitted but limited to validated force and pressure thresholds. It is the method most collaborative-marketed robots are built for, and it must be validated on the actual application, with the actual tooling and part, not assumed from the robot's rating.

Reach

The maximum distance from the robot's base to its tool flange, defining the envelope it can work in. Usable reach is smaller than the datasheet figure once orientation, tooling length, and joint limits are considered, which is one of the things simulation exists to check.

Repeatability and accuracy

Repeatability is how closely the robot returns to a taught position; accuracy is how closely it reaches a commanded coordinate it has never been taught. Datasheets quote repeatability under the standardized performance test, and most applications depend on it, but offline-programmed and vision-guided work depends on accuracy, which is worse and rarely published.

Risk assessment

The systematic identification and reduction of hazards for the specific application, required by the safety standards and owned by whoever integrates the cell. It determines the safeguarding, the safety functions and their required performance, and whether collaborative operation is viable, and no compliant cell exists without a documented one.

Safeguarding devices

The equipment that protects people from the cell: fences and interlocked gates, light curtains, pressure-sensitive mats, and area scanners that slow or stop the robot when a person approaches. The mix is an output of the risk assessment, and scanners and curtains trade floor space against fencing at the cost of engineered stopping distances.

SCARA robot

A four-axis robot rigid in the vertical direction and compliant in the horizontal plane, built for fast, precise pick-and-place and assembly over a small envelope. Where the task fits, it is faster and cheaper than a six-axis arm, and where parts arrive at high speed in a shallow field, its delta-robot cousin does the same job at the same overhead.

Speed and separation monitoring

The collaborative operating method in which the robot runs at full capability when people are far away and slows or stops as they approach, using safety-rated distance sensing. It preserves productivity in shared spaces at the cost of engineered protective distances that must be validated for the actual cell.

Tool center pointTCP

The defined point on the end-of-arm tooling, such as a gripper's grip point or a welding wire tip, whose position and path the robot's motion is programmed around. An inaccurate tool center point definition shows up as mysterious process errors, and re-verifying it after a crash is standard practice.

Tool changer

A coupling between the robot flange and its tooling that allows tools to be exchanged, manually or automatically, passing power, signals, and air or fluid through the joint. It buys flexibility across tasks at the cost of added weight on the payload, one more failure point, and money, so it earns its place only when the application truly needs multiple tools.

Work envelope

The three-dimensional space the robot can reach, published as a diagram in the datasheet. Cell layout lives and dies by it: the parts, the process, and the maintenance access all have to fit inside it, at usable orientations, with safeguarding outside it, which is why layout is simulated before anything is bought.

Standards

Industrial Robot Standards and Certifications: ISO 10218, R15.06, and R15.08

What each standard governs and why a buyer should care. Which ones apply depends on the robot, the application, where the cell is installed, and who integrates it.

Robot and mobile robot safety standards

ISO 10218-1 and ISO 10218-2

Published by the International Organization for Standardization (ISO). The two-part safety standard for industrial robots: Part 1 covers the robot itself, its design and manufacture, and Part 2 covers the integration of robot applications and cells, safeguarding, and the central role of risk assessment. The current revision substantially expanded both parts, absorbed the formerly separate technical specification on collaborative operation into Part 2, added robot classifications and cybersecurity requirements, and made functional safety requirements explicit. It applies to essentially every industrial robot purchase worldwide, directly or through national adoptions. Two practical consequences: collaborative is formally a property of the application, not of the robot, under the current edition; and documentation that still cites the old technical specification as its primary collaborative reference has not caught up with the current standard.

ANSI/A3 R15.06

Published by the American National Standards Institute and the Association for Advancing Automation (A3), with the Canadian counterpart published by the CSA Group as Z434. The United States national adoption of both parts of the international robot safety standard, revised to align with the current international edition, plus a third part, without an international counterpart, covering the use of industrial robot cells. It applies to robots and cells built, integrated, or operated in the United States, and it is the reference an integrator's risk assessment and safeguarding design should cite. Ask which edition a proposal is documented against, because the current revision replaced an edition that stood for over a decade and terminology changed with it.

ANSI/RIA R15.08

Published by the American National Standards Institute and the Association for Advancing Automation (A3). The safety standard for industrial mobile robots, in parts addressing the requirements on the vehicle's manufacturer, on the integration of mobile robots into a site, and on their use, written from the assumption of autonomous navigation rather than fixed guidepaths. It applies to autonomous mobile robots and mobile manipulators deployed in United States facilities. Because a mobile robot's safety depends on the site, the fleet, and the traffic as much as the vehicle, the integration part matters as much to a buyer as the vehicle part, and a deployment quoted without site-level safety engineering is incomplete.

ISO 3691-4 and ANSI/ITSDF B56.5

ISO 3691-4 is published by the International Organization for Standardization through its industrial truck committee; B56.5 is published by the Industrial Truck Standards Development Foundation (ITSDF). Both cover driverless industrial trucks, the standards lineage of automated guided vehicles, specifying safety requirements for the vehicles and their systems, with the international standard applied for European conformity. They apply to guided vehicles and, in Europe, to mobile robots generally. A buyer comparing mobile robot proposals should ask which mobile robot standards each vehicle and deployment is designed to, because the standards make different assumptions about navigation, and the answer reveals the design's heritage.

Machinery safety framework

ISO 12100

Published by the International Organization for Standardization (ISO). The foundational machinery safety standard defines the method of risk assessment and risk reduction: identify hazards, estimate and evaluate risk, and reduce it through inherently safe design, safeguarding, and information for use. It applies to every robot cell because the robot safety standards are built on it and require its process. For a buyer, its practical meaning is that safety deliverables are application-specific documents, not product certificates, and the documented risk assessment for your cell is a contract deliverable to require by name.

ISO 13849-1 and IEC 62061

The International Organization for Standardization publishes ISO 13849-1, and the International Electrotechnical Commission publishes IEC 62061. The two functional safety standards for machinery control systems, one expressing required reliability as performance levels a through e, the other as safety integrity levels. The risk assessment sets the required level for each safety function: an emergency stop, an interlocked gate, a monitored standstill, and the control design must demonstrably achieve it. They apply to the safety-related controls of every cell. Ask the integrator to state the required and achieved levels for each safety function, as that table is the backbone of the safety design.

NFPA 79 and IEC 60204-1

The National Fire Protection Association publishes NFPA 79; IEC 60204-1 is published by the International Electrotechnical Commission. The electrical standards for industrial machinery cover supply circuits, protection, grounding, control circuits, emergency-stop electrical requirements, enclosures, and the marking of the machine's electrical system. NFPA 79 governs machines installed in the United States, and the IEC standard governs them internationally and for CE conformity. They apply to the cell's electrical construction regardless of who builds it, and specify which one, with the plant's supply characteristics, belongs in the RFQ rather than in a change order after the panels are built.

OSHA requirements

Administered by the Occupational Safety and Health Administration of the United States Department of Labor. OSHA has no robot-specific standard; the General Duty Clause and the machinery provisions, including machine guarding and the control of hazardous energy for service and maintenance, govern robot installations. It applies to every United States workplace operating a robot cell, with the employer holding the compliance obligation regardless of who built the cell. The consensus standards are how employers demonstrate that hazards were addressed, which is one more reason the documented risk assessment and the safeguarding design belong in your files, not only the integrator's.

Performance, interface, and market requirements

ISO 9283

Published by the International Organization for Standardization (ISO). The performance standard for manipulating industrial robots, meaning a position together with an orientation, defining how pose repeatability, pose accuracy, path characteristics, and related criteria are tested and reported. It applies whenever robot datasheets are compared, because the repeatability figure on a datasheet is only comparable to another measured under this standard's conditions. It is also the basis for distinguishing repeatability from accuracy: most datasheets publish only the former, while offline-programmed and vision-guided applications depend on the latter, so an application that needs absolute accuracy should say so and ask how it will be achieved and verified.

ISO 9409-1

Published by the International Organization for Standardization (ISO). The standard for the mechanical interface at the robot's tool flange, defining bolt circles, fits, and dimensions for circular plate interfaces. It applies to every end-of-arm tooling purchase because a flange to this standard is what allows tooling, tool changers, and sensors from different suppliers to mount on different robots without custom adapters. Specify the interface designation in tooling RFQs and confirm the tooling supplier is designing to the robot's actual flange, since adapters add weight that counts against payload.

EU Machinery Directive and Machinery Regulation

Issued by the European Parliament and Council of the European Union. The legal framework for machinery safety in the European Union and European Economic Area, under which machinery, including robot cells, carries CE marking against essential requirements, with harmonized standards providing presumption of conformity. The long-standing directive is being replaced by a machinery regulation, with a transition period during which the applicable instrument depends on when the machinery is placed on the market; confirm the applicable instrument for your ship date. It applies if the cell is built in or exported to Europe, and the integrator, as the manufacturer of the completed machinery, holds the conformity obligation, which is worth stating explicitly in cross-border contracts.

Frequently Asked Questions

Industrial Robotics FAQs

Direct answers to the questions buyers ask most often when sourcing in this sector.

Almost always a cell, delivered through an integration project. The robot is a catalog product with a datasheet; the cell is the robot plus tooling, fixtures, part feeding, safeguarding, controls, and programming, engineered to your task; and integration is the service that designs, builds, proves, and commissions it. The robot is usually a minority of the total, with tooling, safeguarding, feeding, and engineering making up the rest, which is why two quotes built on the same robot can differ widely and both be honest. Buy the cell against the acceptance criteria, and choose the integrator with more care than the robot brand, because for most applications, several robots will work, and only a well-run project will succeed.

The task, described honestly: what the cell must do, at what rate, for how many hours and shifts. The parts: drawings or samples, the full range of variants, and the real variation in how they arrive, because part presentation is where automation projects live or die. The process: the machine being tended, the weld, the dispense, or the pack pattern, with its quality criteria. The site: floor space, utilities, the applicable electrical standard, and how people will interact with the cell. And the acceptance expectations: cycle time at rate with your parts, documentation, training, and support. The most commonly missing item is the true part variation, and discovering it during commissioning is the most expensive way to learn about it.

No. Under the current safety standards, collaborative is a property of the application, not the robot: the robot's power and force limiting makes collaboration possible, but whether the application is safe depends on the tooling, the part, the speeds, and the surroundings, all evaluated in the risk assessment. A force-limited robot carrying a sharp part, or moving fast near a face, is not a safe application. The assessment may conclude the cell needs safeguarding after all, or may validate contact limits on the real task. Treat collaborative marketing as a capability claim; ask who performs and documents the risk assessment and validation; and be wary of any proposal that treats fenceless operation, running the robot without physical guarding, the word the marketing will use, as a product feature rather than an engineering result.

Payload is measured at the tool flange and is consumed by everything mounted there, tooling, cables, and sensors, before the part counts; sizing against part weight alone is the most common error. Reach is the geometric maximum, and usable reach is smaller once orientation, tooling length, and joint limits are considered, which simulation checks before purchase. Repeatability is how closely the robot returns to a taught point, measured under the standardized performance test, and it is what most taught applications depend on; accuracy, reaching a commanded coordinate never taught, is worse, rarely published, and is what offline-programmed and vision-guided applications, where a camera locates the part, and the robot must move to coordinates it was never taught, depend on. If your application needs accuracy, say so explicitly and ask how it will be achieved and verified.

In the United States, the national robot standard adopts the international one, including its integration part and the national part on cell use, sitting on the machinery safety framework: the risk assessment method, the functional safety standards that set performance levels for safety functions, the electrical standard for industrial machinery, and the employer obligations under federal workplace law. In Europe, the machinery legal framework includes CE marking, compliance with the international robot standard, and the equivalent electrical and functional safety standards. In both cases, the integrator owns the cell's risk assessment and safety design, and the current revision of the robot standards has folded collaborative requirements into the main standard, so check which editions a proposal cites.

An automated guided vehicle follows fixed guidepaths, in the lineage of the driverless industrial truck standards; an autonomous mobile robot navigates by sensing and planning, covered by the industrial mobile robot standard written for autonomous navigation, whose parts address the vehicle, its integration into a site, and its use. In contrast, the industrial truck standard applies to guided vehicles and serves European conformity. The label matters less than the design basis: ask which standard the vehicle and the deployment are engineered to, because the standards assume different behavior around people. And remember that mobile robot safety is a site property as much as a vehicle property. Hence, a proposal without site-level safety engineering, traffic, and fleet considerations is not yet a proposal.

Responsibility layers. The robot manufacturer is responsible for the robot meeting its part of the safety standard. The integrator, as the party who creates the application, owns the risk assessment, the safeguarding design, the achieved performance of the safety functions, and, in Europe, the conformity of the completed machinery. The employer is responsible for the safe operation of the installed cell under workplace law, including maintenance procedures and hazardous energy control. That obligation cannot be delegated to a vendor. The practical consequences: name the risk assessment and safety documentation as contract deliverables, require the table of safety functions with required and achieved levels, and keep all of it in your files, because in an incident the question lands on the employer first.

Because the robot is the mass-produced part of a custom machine, around it, the cell needs end-of-arm tooling engineered to your part, which is routinely the hardest engineering in the project; safeguarding designed from the risk assessment; part feeding and fixturing, which grow expensive exactly as your parts arrive less predictably; controls and integration with your equipment; and the engineering, programming, commissioning, and acceptance testing that turn hardware into a working cell. The proportions vary by application, but the pattern does not, and it is why simplifying part presentation and reducing variants before automating often does more for the price than negotiating the robot. A quote surprisingly close to the robot's price is missing scope you will pay for later.

A factory acceptance test at the integrator's site before shipment and a site acceptance test after installation, each against criteria agreed in the contract. The criteria that matter: cycle time at rate, run with your real parts across their actual variation, not golden samples, the hand-picked ideal parts a demonstration is tuned to quality outcomes measured the way production will measure them; availability over a defined run; verification of every safety function against the safety design; and delivery of documentation, programs, the risk assessment, spare parts lists, and training. Tie payment milestones to both tests, and resist compressing the factory test to save schedule, because problems found at the integrator's site cost days and the same problems found on your floor cost weeks.

Buyer's Guides

Guides for Sourcing Robotics and Integration

In-depth guides covering the decisions above.

Buyer's Guide

Choosing a Robotic Integrator: Cells, Cobots, and End-of-Arm Tooling

Define the application first, then scope boundaries, the safety case and who owns it, end-of-arm tooling, acceptance testing, and long-term support.

Read the guide

More coming

This sector is growing.

Additional guides are added when there is something genuinely worth saying, not on a schedule. IWS is committed to providing educational content to help you find the right suppliers!

Downloadable Resources

Industrial Robotics Downloads: Checklists and Reference Tools

Practical tools you can take into a supplier conversation.

Find a verified robotics and integration supplier

Search the network for verified manufacturers, distributors, and service providers in this sector.

Every supplier verified · No pay-to-rank

Can't find it? We'll find it for you, free.

Tell us exactly what you require. Our team has spent 30+ years in industrial supply chains, and we'll track down qualified suppliers within one business day. No cost, no obligation.

Request Free Sourcing Help
